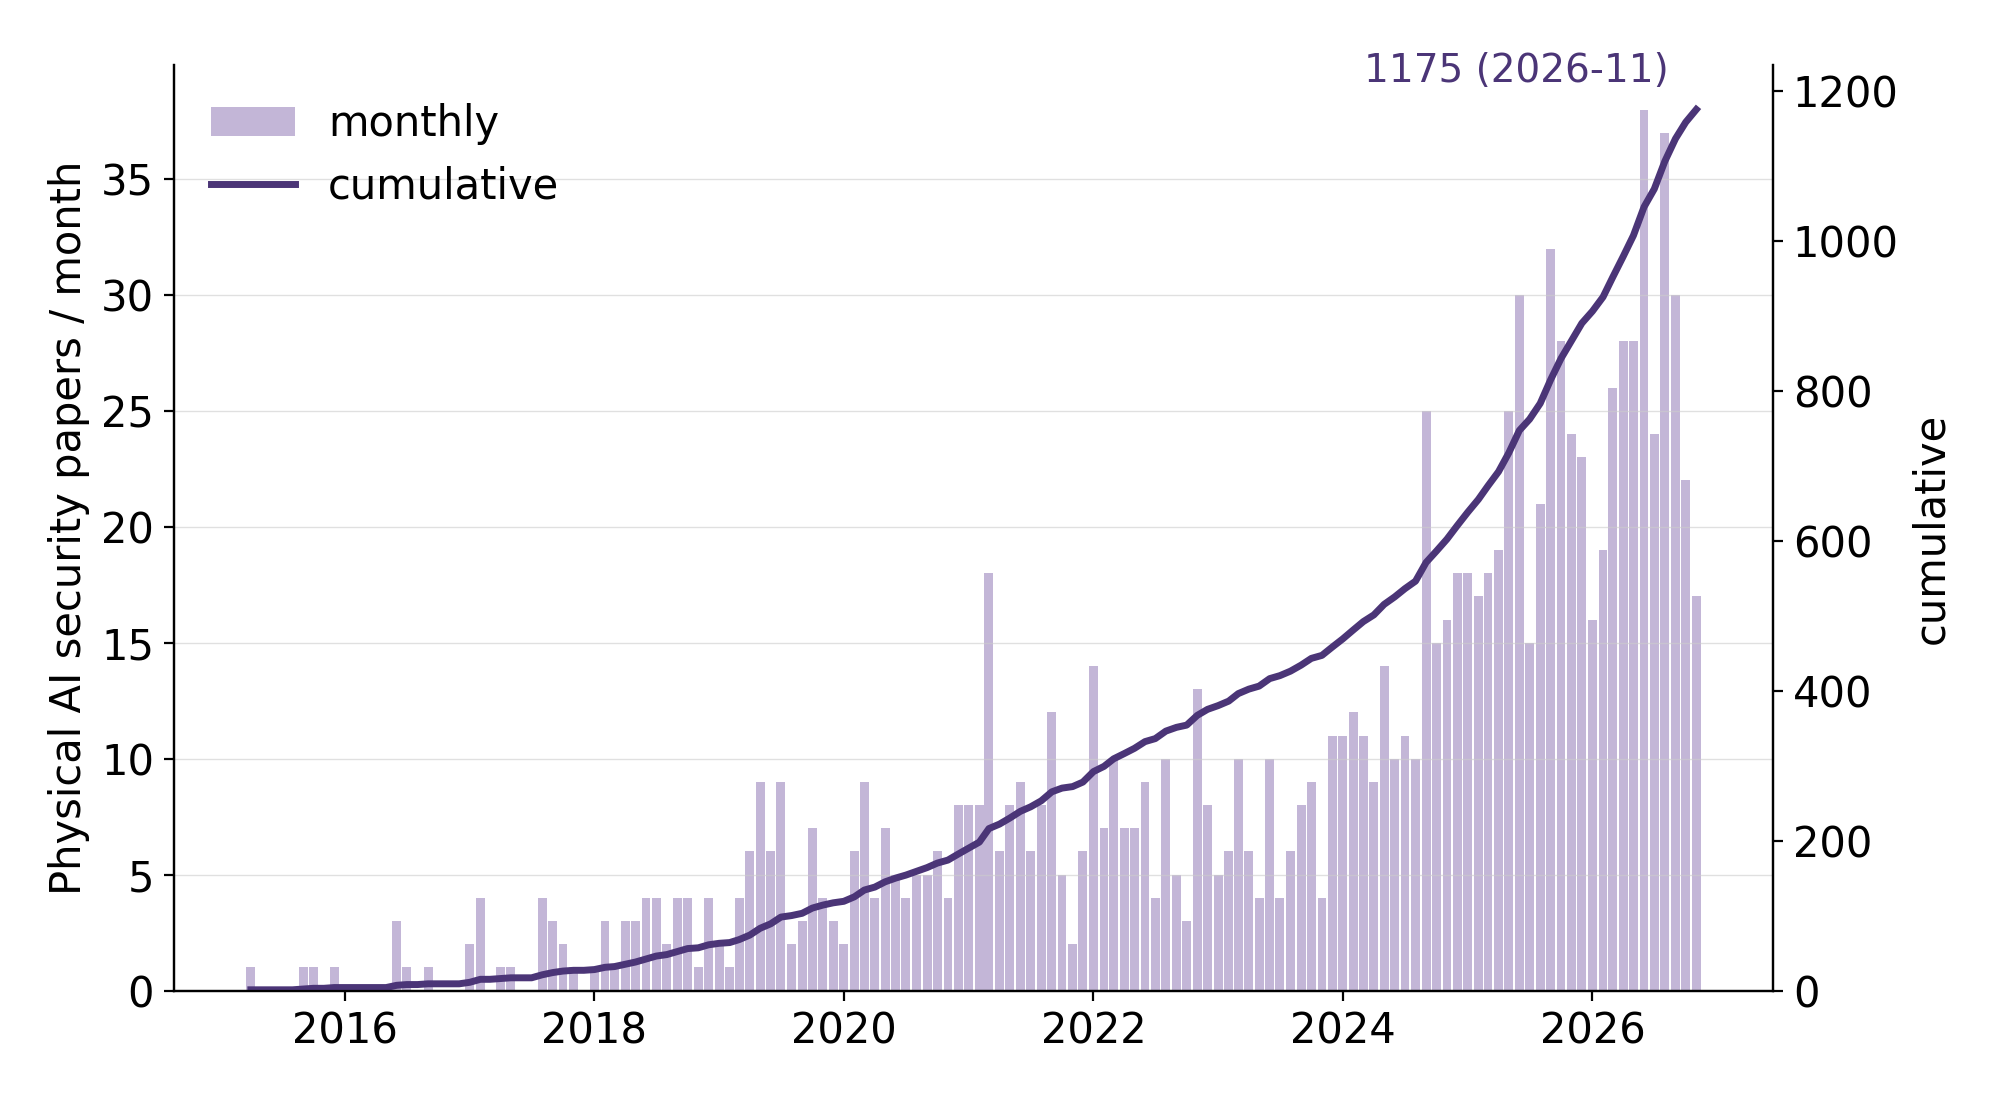
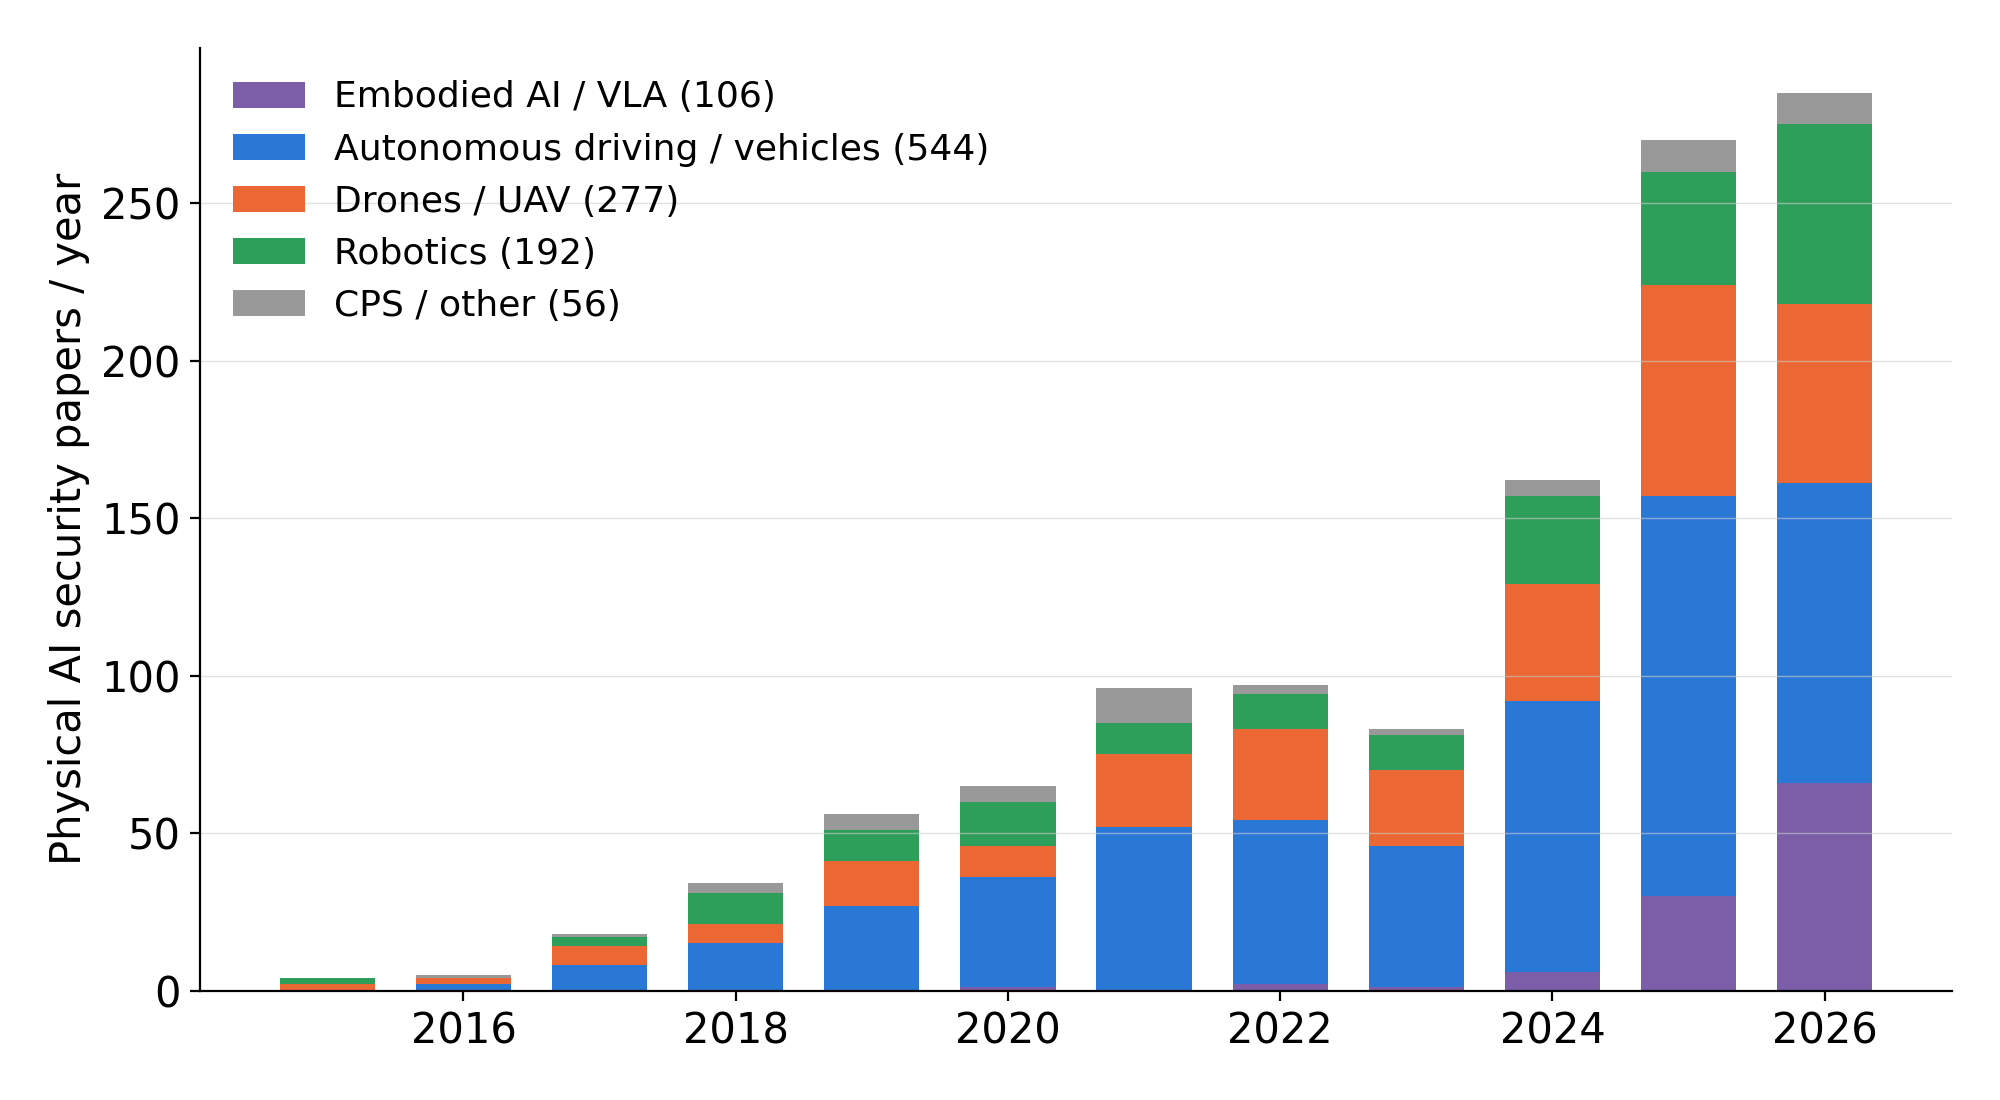
arXiv papers on the security (attacks and defenses) of AI-driven cyber-physical systems:
autonomous driving, robotics, drones/UAVs, and embodied AI. Harvested from
cs.LG, cs.CV, cs.CR, cs.CL, cs.AI, stat.ML, eess.IV, cs.RO, eess.SY, cs.SY
since 2013. Keyword harvest + distant-supervised TF-IDF/logistic-regression filter; confidence in brackets.
Total: 1175 papers.
Last update: 2026-11-21.
Full list (1175 papers, all months): https://nsl.cs.waseda.ac.jp/papers/physec_papers.html
Download: CSV
Download: CSV
Most recent months
2026-11 (17 papers)
- [94%] Embodied AI / VLA When Backdoors Can Be Switched Off: Suppression-Aware Backdoor Attacks on Vision-Language-Action Models
Nur Afsa Syeda; Mohamed Elmahallawy - [94%] Drones / UAV Detecting Formation-Preserving GNSS Spoofing of UAV Swarms through Transmitter Parallax in Pseudorange and Doppler
Minseok Park; Joon Soo Yoo - [93%] Drones / UAV Stealthy Malicious Interference Detection in UAV Formations: A Power-Domain Signaling Game Approach
Jianle Ba; Shaolong Guo; Yuntao Wang; Xin Wu; Zhou Su; Zhendong Li - [93%] Embodied AI / VLA ExecGap: Exploiting Command-Execution Gap for Patch Attacks on Vision-Language-Action Models
Keke Tang; Guolin Qiu; Tianyu Hao; Daizong Liu; Yikai Zhang; Peican Zhu; Zhihong Tian - [89%] Embodied AI / VLA RECLAIM: Robot-Vision-Informed Adversarial Patch Defense via Embodied Attention Feedback
Jiayou Zhu; Peng Guo; Litian Zhang; Xinze Shi; Yuting Zhang; Zelong Yu; Yize Tian; Jirong Liu; Zifeng Kang - [86%] Embodied AI / VLA Robustness as a Transferable Skill: Cross-Task Adversarial Defense for Vision-Language-Action Policies
Jinquan Zhang; Run Yang; Dongfu Yin; Qiang Lai; Yufeng Yan; Pengshuai Yin; F. Richard Yu - [85%] Robotics From Attack Tree to Model Checker: Binding CAPEC Patterns to Verify Robotic System Security
Juel Hussain; Louise A. Dennis; Clare Dixon; Marie Farrell - [84%] Robotics Network-Exposed Configuration Attacks on LLM-Controlled Social Robots
Stanley Akingbola; Ugbede Ibrahim; Yan Lin Aung; Quang Dan Le; Hong Qing Yu - [81%] CPS / other Gradient-Based Defensive Poisoning Against System Identification Attacks on Cyber-Physical Systems
Gonçalo Fernandes; José CecÃlio; Victor Mattos; Daniel S. Menasché; Amit Bhaya; Alan Oliveira de Sá - [80%] Embodied AI / VLA DMT-Attack: Diffusion-Prior Texture Search for Closed-Loop Vision-Language-Action Policies
Jun Xia; Shangwen Wang; Jun Ma; Ruichao Ren; Zhouyang Jia; Xin Zhao; Huijun Liu; Jie Yu - [77%] Robotics Data Manipulation Attacks Against Machine Learning Integrated Cyber-Physical Systems
Soyon Choi; Scott Alfeld; Meiyi Ma - [77%] Autonomous driving / vehicles STA: A Split Temporal Adversary Method for Evaluating Robustness of Multimodal RL-based Driving Policies
Shenghao Xiong; Xiaolin Chang - [75%] Autonomous driving / vehicles Adversarial Tracking: Attacks on Image Sensors for Object Tracking in Autonomous Vehicles
Han Wu; Alex Chan; Ekin Can Erkus; Tousif Rahman; Rishad Shafik - [70%] Embodied AI / VLA Say the Same, Act Differently: Diagnosing and Steering Text-Action Divergence in Reasoning VLAs
Zihao Feng; Qingzhao Zhang; Chunyu Xia; Bo Yu; Z. Morley Mao; Ramesh Govindan - [68%] Drones / UAV Guarded Swarms in the Loop: A ROS 2/PX4 Digital Twin for Hybrid Digital-Analog Coordination of UAV/UGV Swarms
Uwe M. Borghoff; Paolo Bottoni; Luca D'Aurizio; Remo Pareschi - [56%] Embodied AI / VLA Cumulative and Audited Guardrail Tool Evolution for LLM Agent Safety
Xiao Yang; Aishan Liu; Siyuan Liang; Zonghao Ying; Le Wang; Jiakai Wang; Xianglong Liu; Dacheng Tao - [51%] Drones / UAV Attack-Aware Intrusion Risk Monitoring for Aerial Surveillance via Probabilistic Signal Temporal Logic
Xinhao Yan; Kenji Kashima; Bo Chen; Hailong Huang
2026-10 (22 papers)
- [94%] Embodied AI / VLA Detect and Suppress: A Mechanistic Defense against Adversarial Patches in VLA Models
Yukiya Horiba; Koshiro Aoki; Shunsuke Yasuki; Bum Jun Kim; Taiki Miyanishi - [92%] Autonomous driving / vehicles Transferable Spatial Temporal Coherence Adversarial Attack on Black-Box Vision Language Models for Autonomous Driving
Heyam Bin Jahlan Areej Alhothali Abeer Alhothali - [90%] Drones / UAV Defense-in-Depth at the Perception-Reasoning Interface of LLM-Centric Agentic UAV Swarms
Mohammadhossein Homaei; Yousef Emami; Sajad Homayoun; Rahim Taheri; Hao Zhou; Miguel Gutierrez Gaitan; Bo Wei - [89%] Autonomous driving / vehicles Can Autonomous Vehicles Keep Their Cool? A Survey of Thermal Side-Channel and Perception Attacks
Harsh Aaryan; Ce Zhou - [88%] Embodied AI / VLA Black-Box Adversarial Patch Attacks on VLAs via Ancestor VLM Exploitation
Xiaoyi Pang; Haoyue Feng; Quanxin Shou; Yikun Miao; Zhengyang Yan; Song Guo - [88%] Embodied AI / VLA Enhancing Visual Task-Redirection Attacks on Vision-Language-Action Models via Closed-Loop Optimization
Chunjin Ye; Guanying Chen; Jianjie Huang; Jianhao Chen; Quanlin Chen; Hanjie Zhao; Haozhe Liang; Tieyun Qian; Xiaochun Cao - [87%] Drones / UAV Receiver-Domain Behavioral Probing for Backdoor-Resilient Federated GPS Spoofing Detection in UAV Networks
Will Jedrzejczak; Cole Walther; Dilpreet Gill; Moh Khalid Hasan - [85%] Drones / UAV Defending Consensus-Based Cooperative Sensing Against Conformity-Driven Byzantine Attacks in 6G UAV Swarm Networks
Ruixing Ren; Junhui Zhao; He Fang; Xiaoke Sun; Jiamin Li; Pengcheng Zhu; Dongming Wang - [85%] Robotics PhantomTac: Hijacking Robotic Tactile Systems with Deploy-and-forget Tags
Binbin Zhang; Yifeng Zhang; Xiaomeng Chen; Dongyao Chen - [83%] Embodied AI / VLA Benchmarking Jailbreak Guardrails for Embodied Agents
Xunguang Wang; Qingyue Wang; Yuguang Zhou; Zongjie Li; Wenxuan Wang; Shuai Wang - [81%] Robotics Lie Rarely, Lie Big: Stealthy Insider Attacks on LLM Robot Teams
Sribalaji C. Anand; George J. Pappas - [79%] Embodied AI / VLA TMT: Runtime Backdoor Detection for Vision-Language-Action Policies on Unseen Tasks
Zirun Zhou; Jingfeng Zhang; HaoChuan Xu; Xizhe Zhang; Elliott Wen; Jing Sun; Hong Jia - [79%] Autonomous driving / vehicles Adversarial Robustness of Camera-Radar Sensor Fusion for Autonomous Driving
Ce Zhou; Yubo Wu; Khang Nguyen; Liyang Xiao; Thomas Hou; Qiben Yan - [79%] Autonomous driving / vehicles LiDAR-SHIELD: A Fully Dockerized Adversarial Robustness Assessment Framework for LiDAR-Based 3D Perception Models
Alexandros Gkillas; Ioulia Kapsali; Christos Anagnostopoulos; Aris S. Lalos - [78%] Robotics Refuse the Harm, Complete the Task via Graph-of-Rules Planning for LLM-Enabled Robots
Ali Taheri; Alireza Taban; Qizhou Wang; Wanhua Li - [77%] Embodied AI / VLA From bits to atoms: A survey of cross-layer safety in Embodied AI
Tuo Feng; Yue Zhang; Shiji Zhou; Zhaoxin Fan; Wenguan Wang; Xiaowei Chi; Tianyu Shen; Xiangtai Li; Xuesong Bai; Zheng Zhu; Sirui Han; Boyu Zhou; Zhaosong Wang; Shizhe Chen; Zilong Zheng; Chenjia Bai; Jiangmiao Pang; Yaodong Yang; Hao Zhao; Di Hu; Li Yi; Yan Huang; Qi Wu; Hanwang Zhang; Fei Gao; Shanghang Zhang; Hongsheng Li; Jianye Hao; Yuan Zhang; Yingjie Xia; Jian Shen; Cewu Lu; Hui Zhang; Kai Chen; Wenwu Yu; Badong Chen; Jungong Han; Yike Guo - [75%] Autonomous driving / vehicles A Secure dToF LiDAR SoC with Dual-Domain Fingerprinting and Event-Driven AFE Circuit Achieving Sensor-Level Attack Resilience
Risa Nonaka; Ryoya Matsuno; Shota Nagai; Satomi Miyagi; Yuki Hayakawa; Ryo Suzuki; Kazuma Ikeda; Ozora Sako; Rokuto Nagata; Ryo Yoshida; Shimpei Ando; Wenlun Zhang; Kentaro Yoshioka - [75%] Robotics Program-Level Adversarial Co-Adaptive Self-Play for Robotic Security
Leo Benaharon; Chi Zhang; Wei Zheng; Weifan Zhang; Yifan Wei - [73%] CPS / other AquaSense-ICS: A Hybrid Real-Simulated Cyber-Physical Dataset and Leakage-Aware Benchmark for Smart Water Quality Monitoring and Attack Detection
Amal Neji; Mohamed Fourati; Lamia Chaari Fourati - [67%] Autonomous driving / vehicles SafeDriveVLA: Navigation-Conditioned World Model Dreaming for Conflict-Aware End-to-End Autonomous Driving
Shaoyuan Xie; Zihan Zhang; Jingxuan Wang; Jiashu Qu; Xiaoqing Liang; Lingdong Kong; Junchi Lu; Henrik I. Christensen; Qi Alfred Chen - [54%] Autonomous driving / vehicles Towards Effective and Transferable Physical Camouflage against Multi-View BEV-based 3D Perception in Autonomous Driving
Linye Lyu; Jiawei Zhou; Daojing He; Yu Li - [54%] Drones / UAV Sybil-Resilient Multi-Drone Exploration of Indoor and Confined Spaces
Shyaam Mahesh; Aditya B Prakash; Rubal Sagwal; Avinash Gautam